Off-Road Autonomy

Train, test, and evaluate anywhere — before tires ever hit the ground

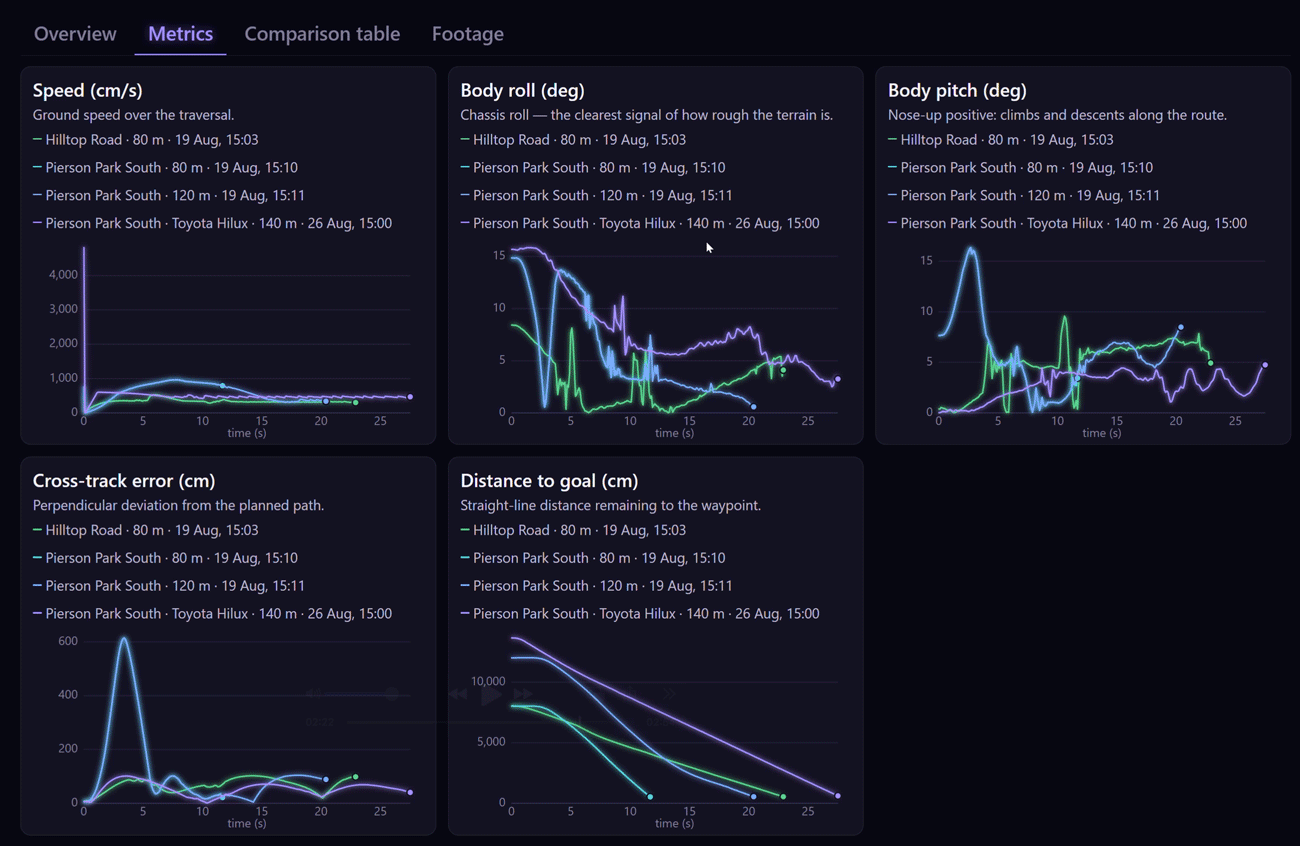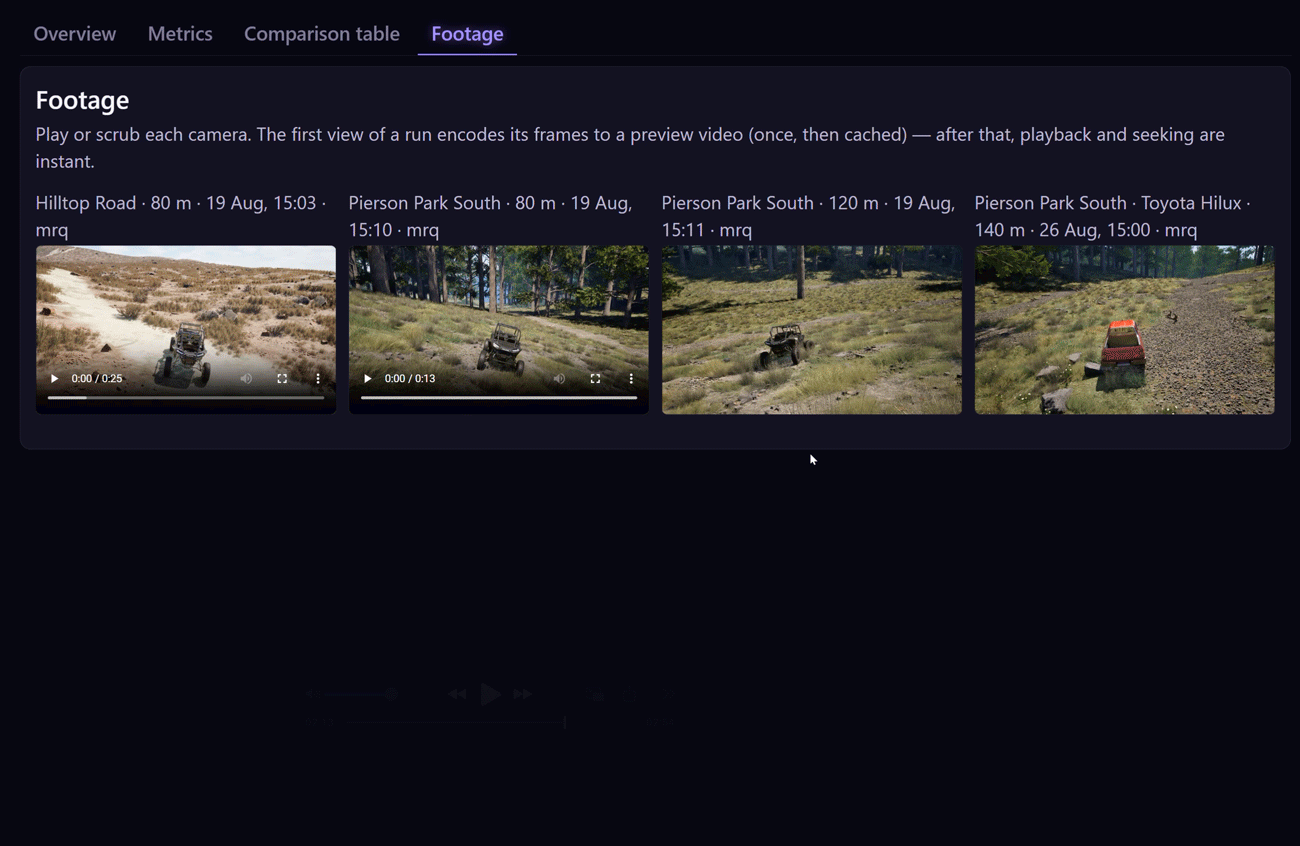
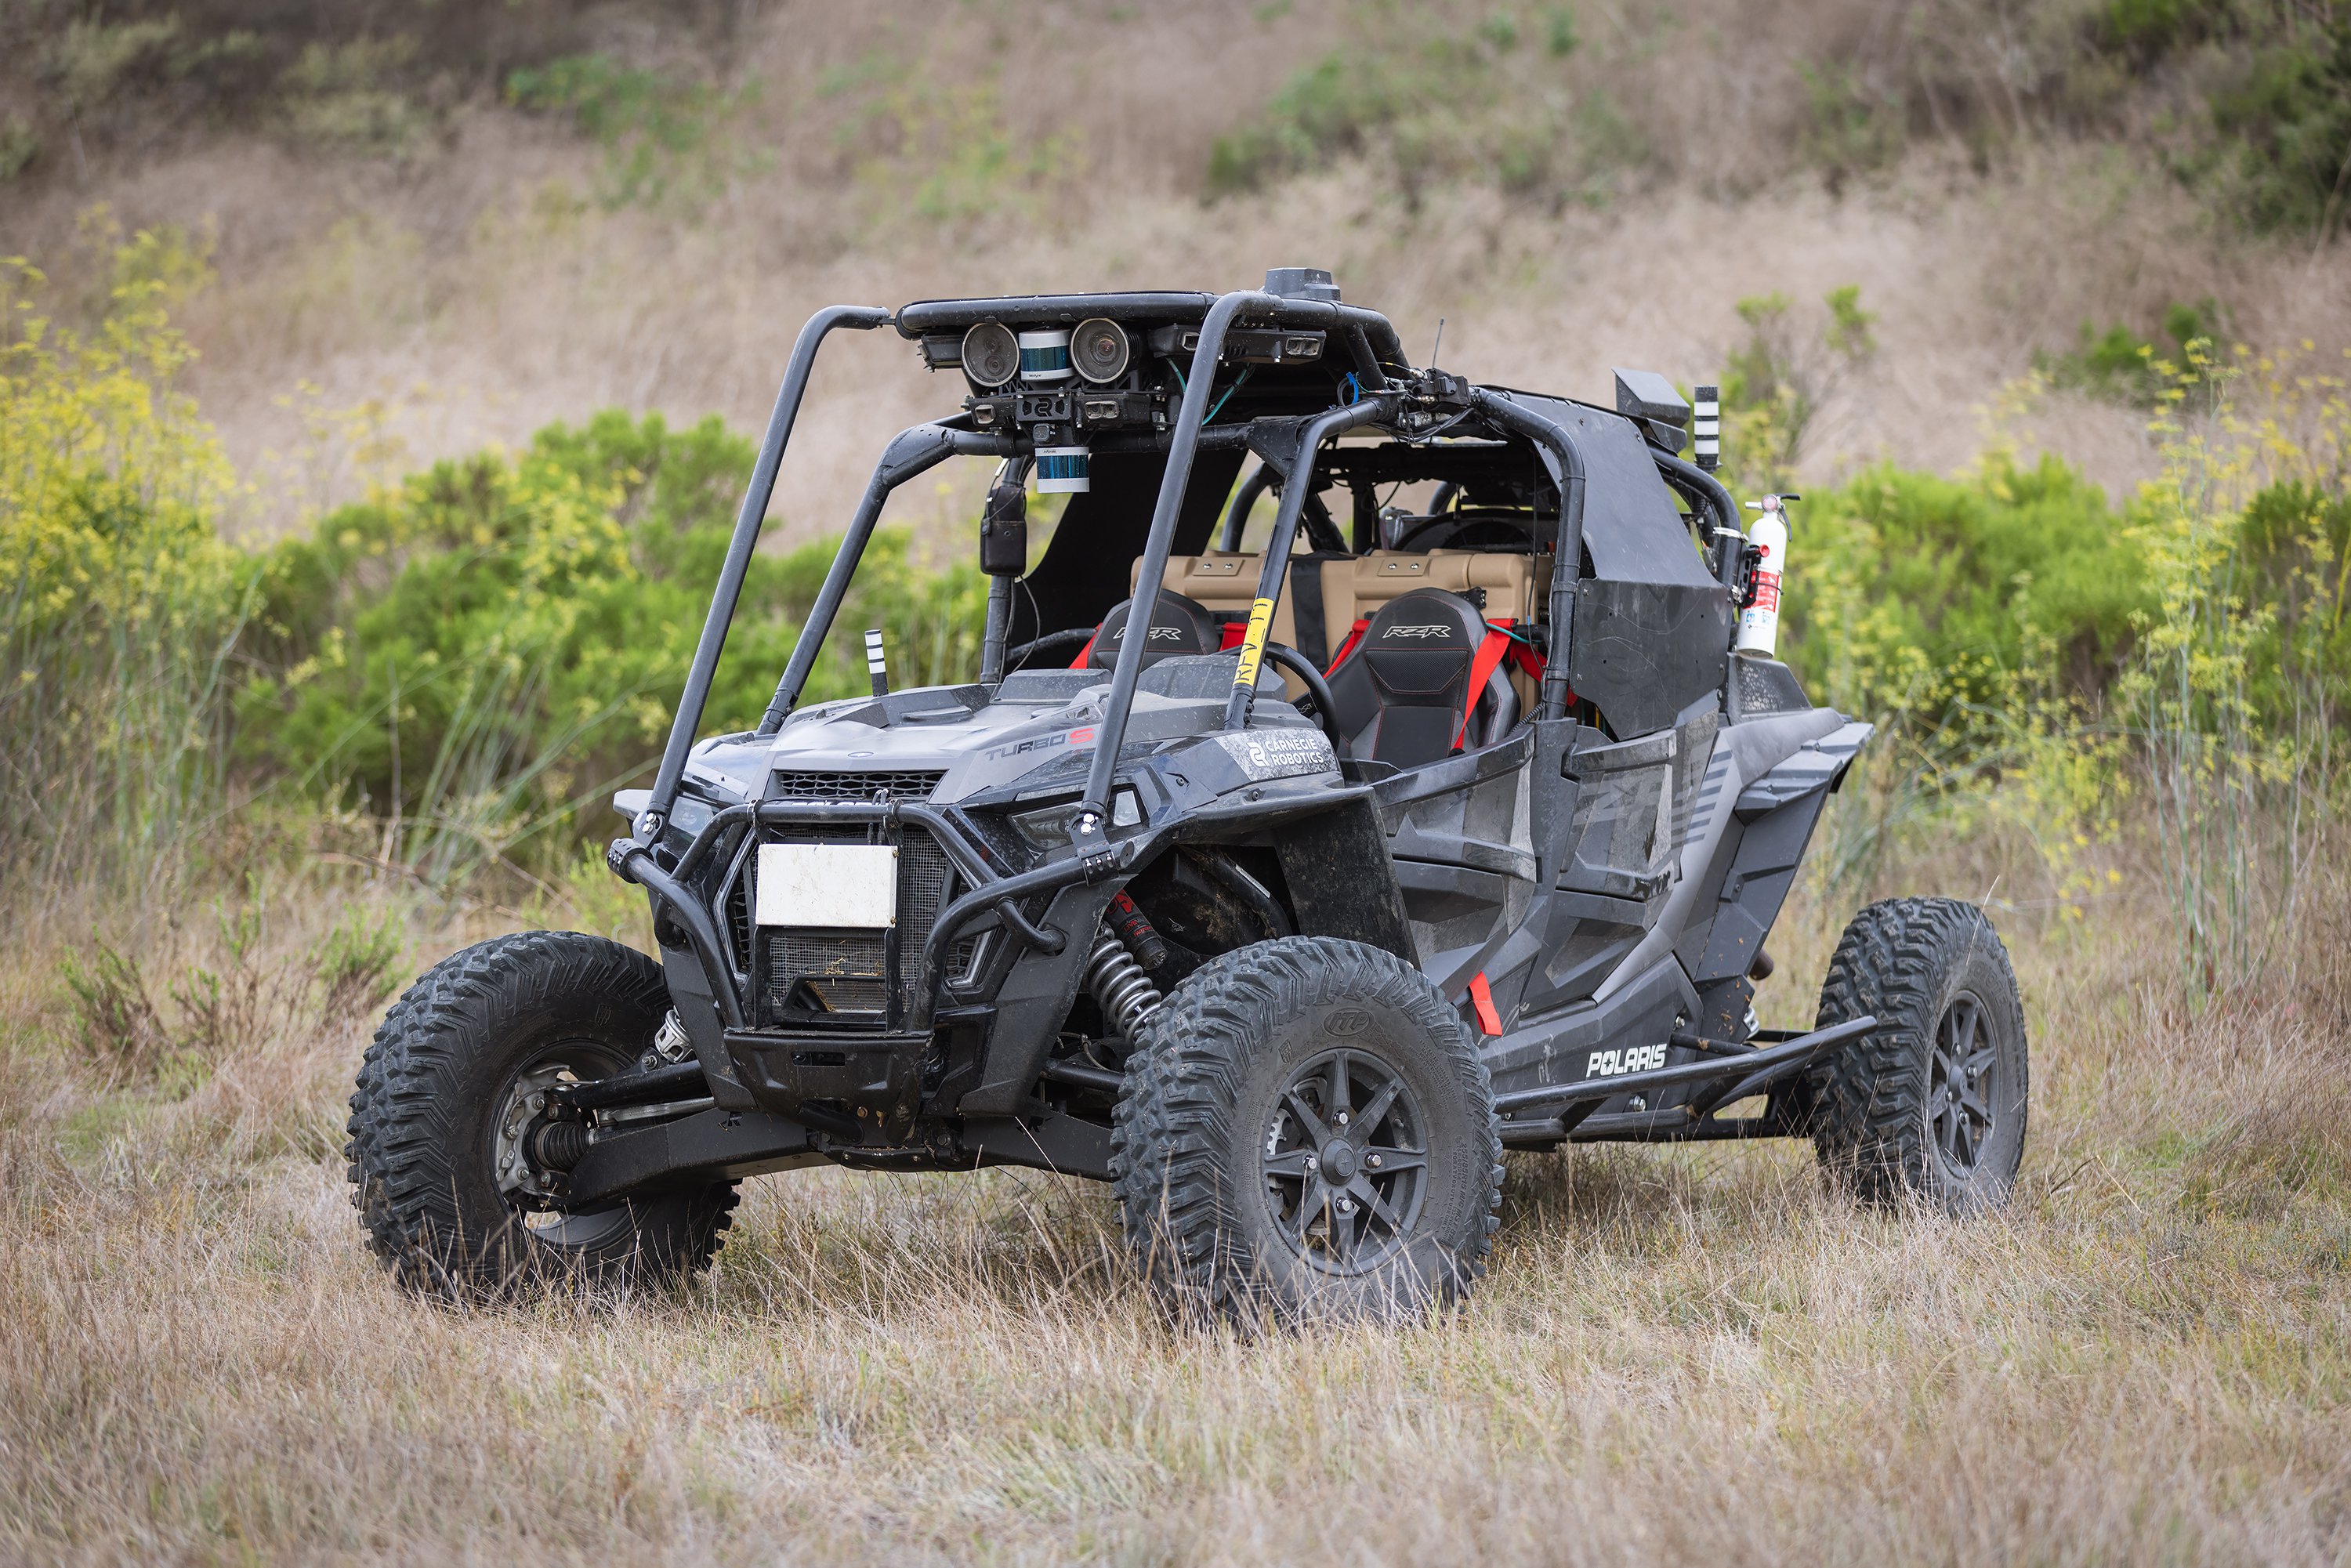
Real world terrain is a non-stop obstacle: ruts, streambeds, loose slopes, vegetation with no clear line of sight. Hazards that traditional sims never tests. Falcon combines physically-grounded virtual sensors with digital twins of your environments and biomes, giving unrivaled options for building confidence in your model.
‍

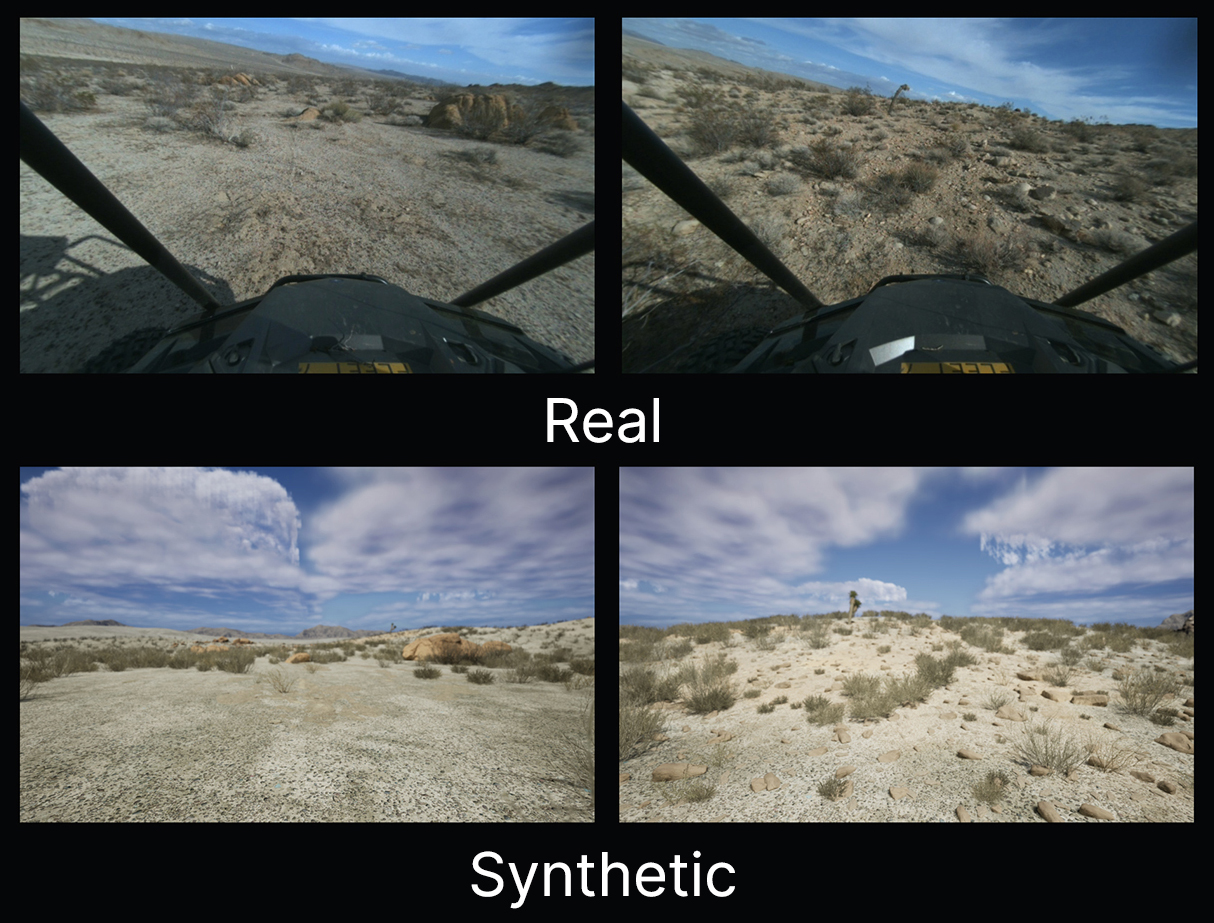
Our results are proven to close the sim-to-real gap, while dramatically reducing both costs and timelines. Find where your model struggles with traversability, and fix it fast. Ever hazard and edge case discovered in simulation is one your vehicle never has to survive in the field.
Book a demo
We'll reach out to discuss your project
See the results
See our approach in the real world
Digital Twin Environments and High-Fidelity Sensors Built for Any Mission
  • • Train and test your autonomy stack in high-fidelity digital twins of the locations it will actually operate in.
    ‍
  • • Find traversability, perception, and navigation failures early, then generate the targeted data needed to close edge cases and fill gaps in your training set.
High-Performance LiDAR & Seamless Autonomy Integration
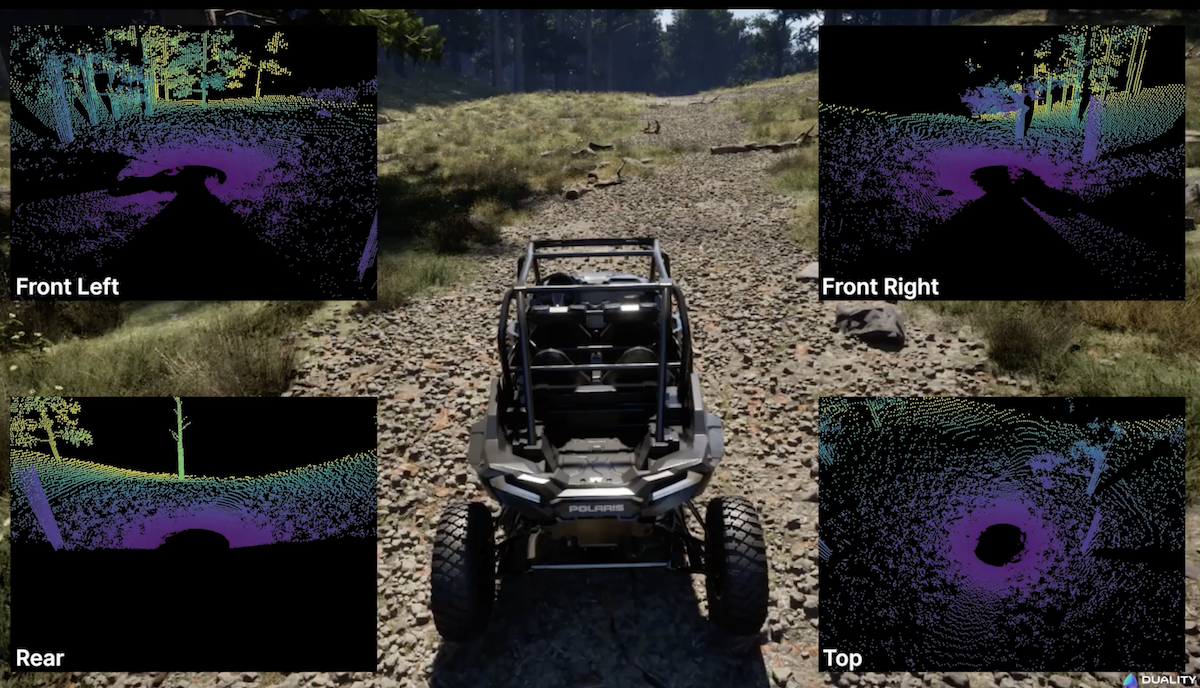
  • • Run multiple instances of high-performance LiDAR fast enough for demanding autonomy workflows
    ‍
  • • Support for multi-return sensing and out-of-the-box integration with industry standards like ROS2 and NAV2
    ‍
  • • Connect Falcon to any real robotics stack and test perception and navigation in realistic terrain, and evaluate how the system behaves before taking it into the field
Continuous Performance Evaluation and Experimentation — At Scale
  • • Run training, testing, and synthetic data generation continuously across large batches of scenarios.
    ‍
  • • Launch experiments headlessly and with varied terrain and operating conditions
    ‍
  • • Surface failure cases at scale to improve autonomy stacks faster
High-Fidelity Sensors for Accurate Training, Testing, and Eval
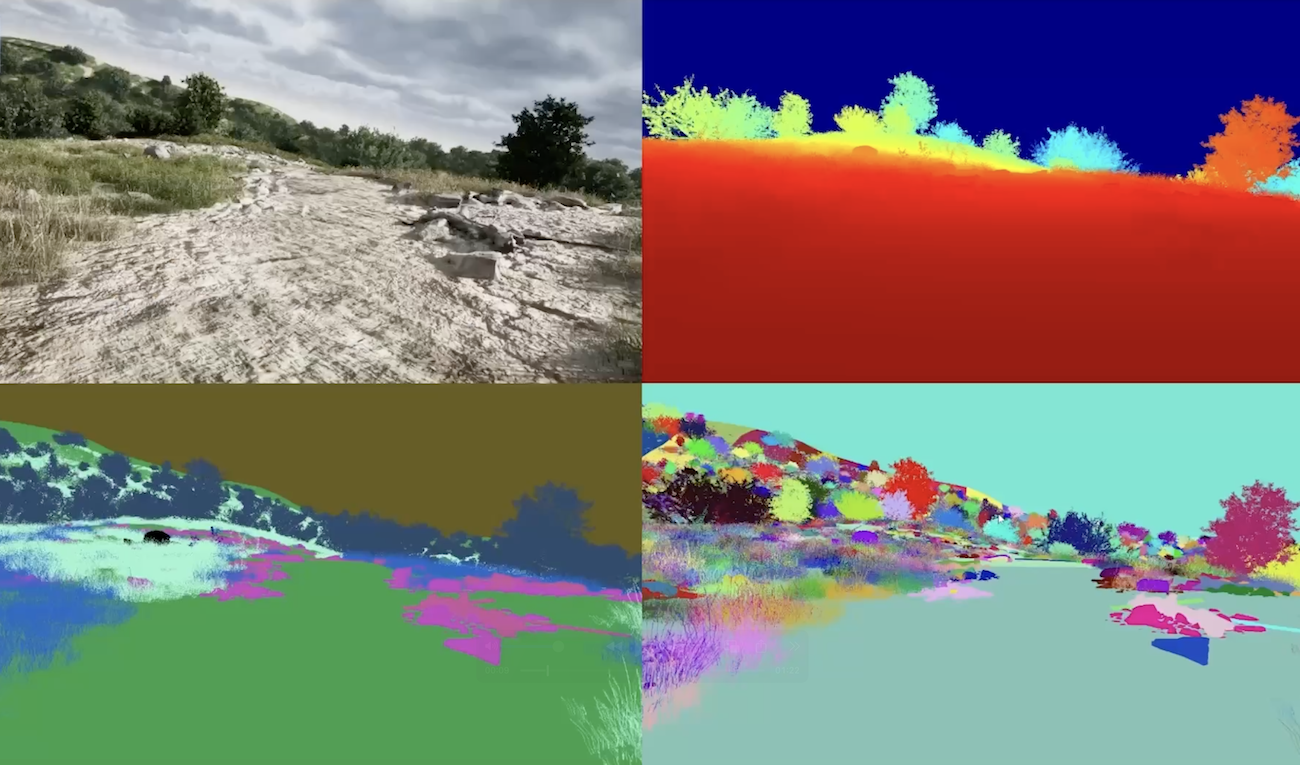
  • • Physically-grounded, high-fidelity sensors, including: LiDAR, EO, IR/Thermal, SAR, IMU, GPS, and more — all customizable to match any real world system
    ‍
  • • All streams generated from same ground truth, deterministically, and with synchronized timestamps
Book a demo
We'll reach out to discuss your project
See the results
See our approach in the real world